New legs with 12 degrees of freedom
Each leg now has six joints, more than the previous design. What the new legs can do and how they are built.
The legs are the hardest part of a humanoid robot. For Kourai we redesigned them from scratch: two legs with six degrees of freedom each, twelve servos in total.
Key data
| Property | Value |
|---|---|
| Degrees of freedom | 2 × 6 DOF |
| Servos | 12 units, 40 × 40 × 20 mm |
| Leg length | approx. 43 cm |
| Material | PETG-CF |
| Printer | Bambu Lab P1S (AMS) |
Before and after
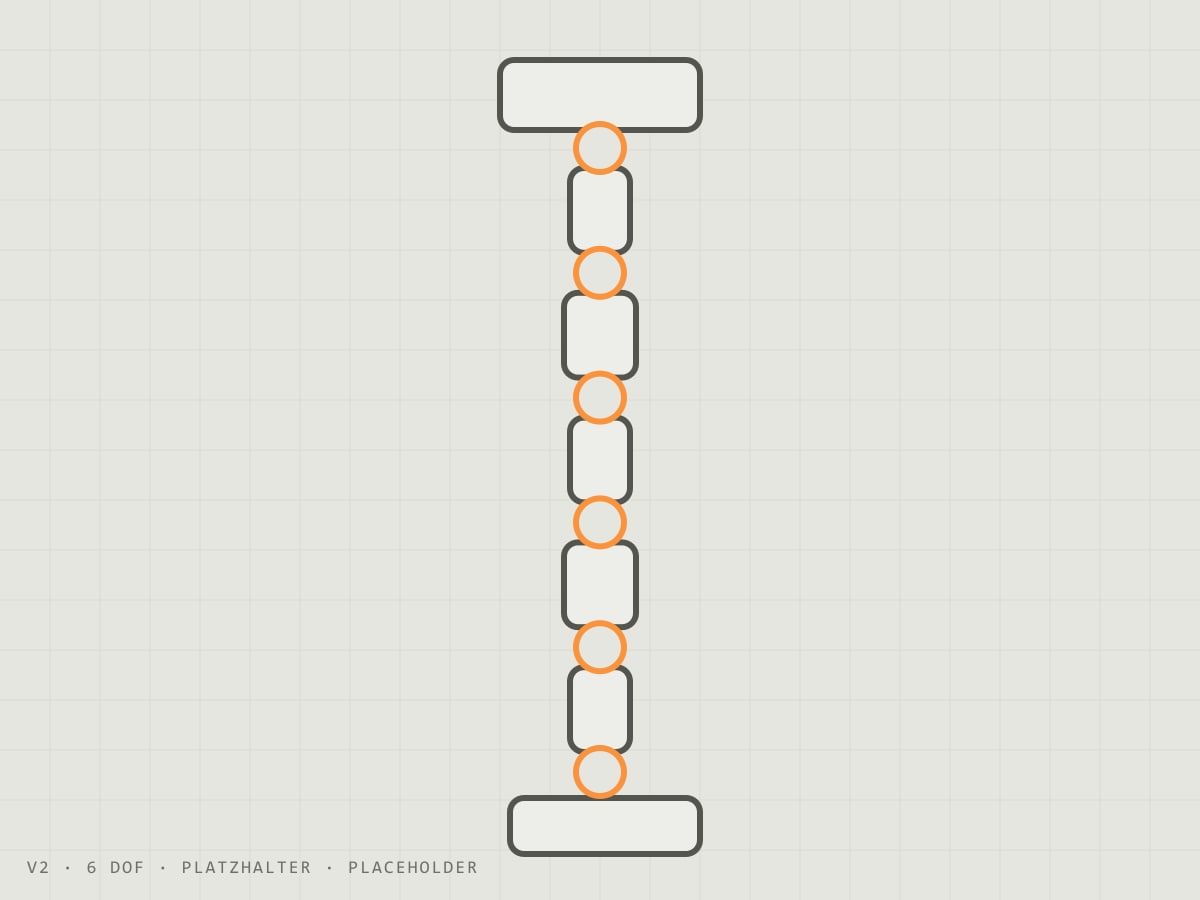
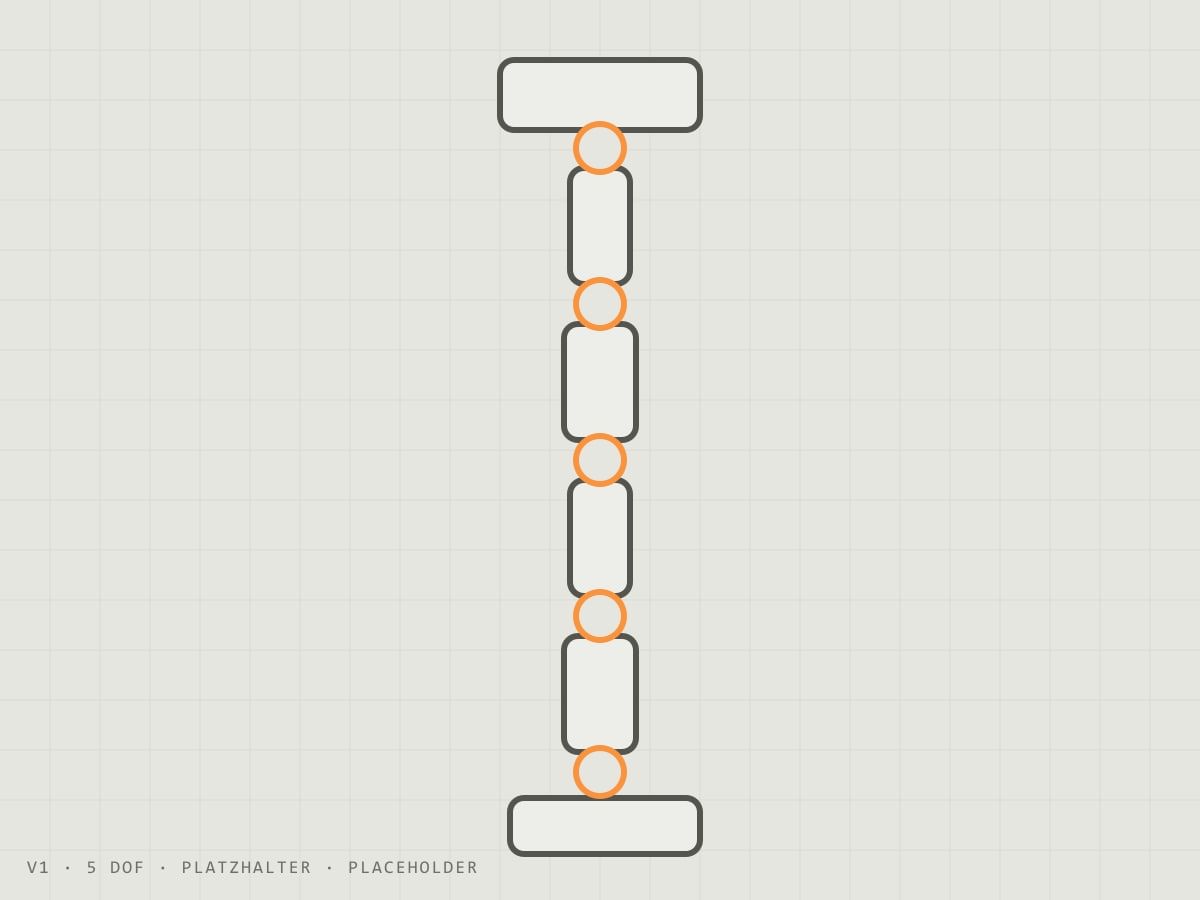
What comes next
The first standing tests are next. The design details are in the leg design documentation.